
So, after that lengthy introduction, this is a memo about my experience actually trying out “Quick mastering.”
Note:
The latest robot OS has a method called Quick Mastering (Master using power-off position), which is simpler.

This method is not available in older robot OSs.
① Pulse Reset
First, we need to eliminate the alarm, so we will perform a pulse reset to clear it.
From the menu, go to System → System Variables, select $MCR.$SPC_RESET, and press F4 TRUE.
It will briefly show TRUE, then immediately change to FALSE.
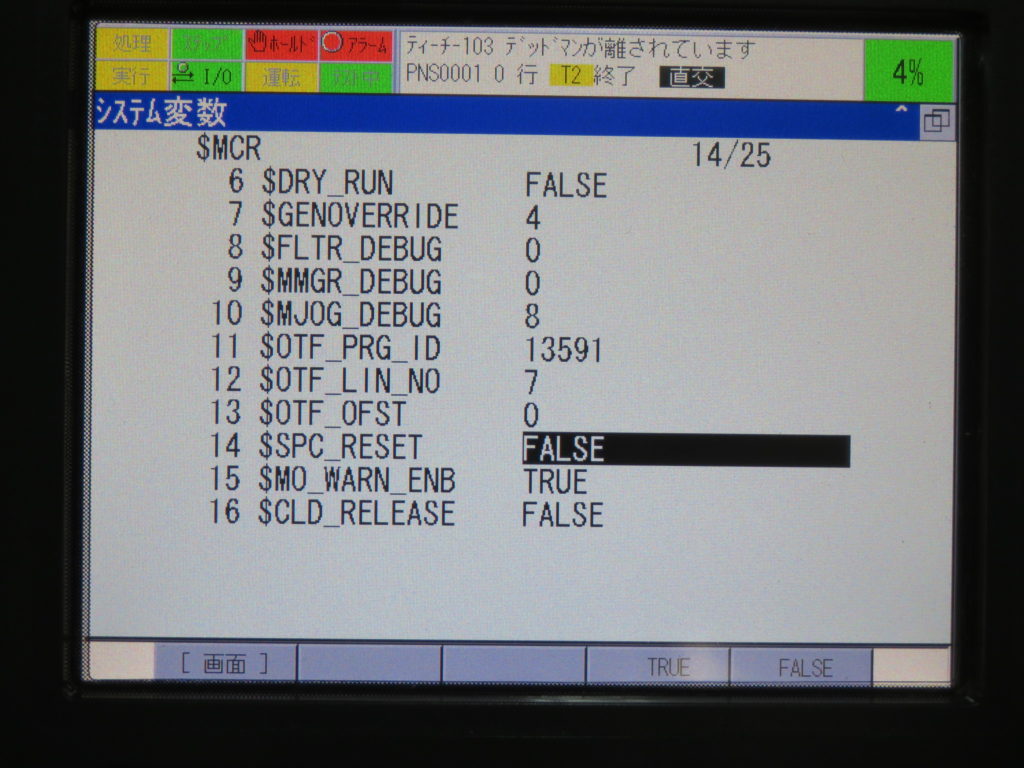
Pressing the alarm dismiss button will clear the “SRVO-062 BZAL alarm,” allowing you to operate each axis. You still cannot operate it orthogonally.
If the alarm does not clear at this point, restart the power.
(It seems that you can also perform a pulse reset by going to System → Alignment in the menu, pressing F3 Pulse Reset, and then F4 Yes.)
② Using the teaching pendant to align each axis to the zero position
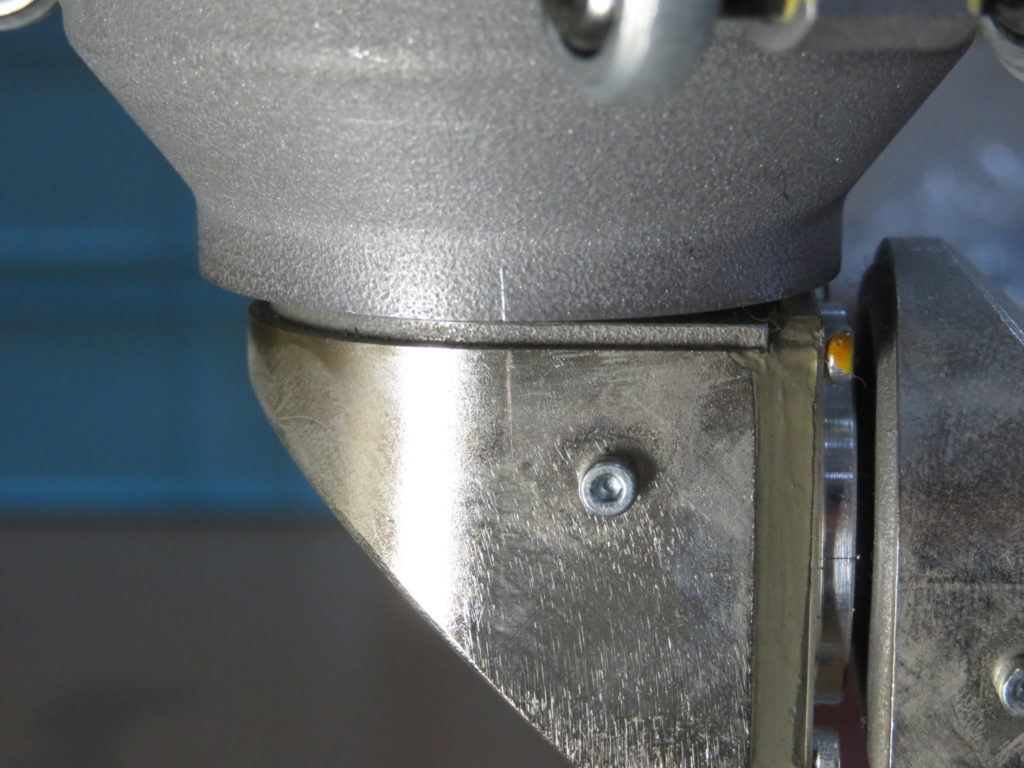
, align the zero position mark (alignment mark) scribed line on each axis.
The location of the alignment mark is shown in the instruction manual for each robot’s mechanism.
In this case, since it was the M-1iA fist robot, we aligned all six axes with the scribed lines as shown in the following photo.
The alignment mark scribed lines are very thin, so you can’t see them unless you look carefully.

③ From the Quick Mastering
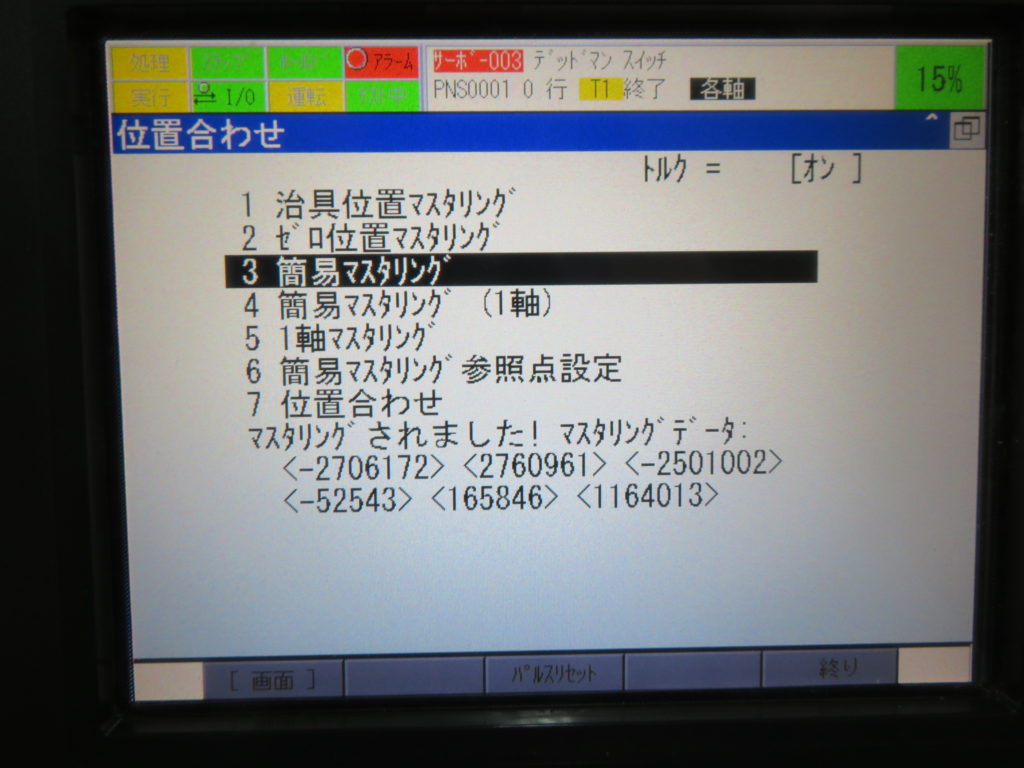
menu, select System → Master/Cal → “Quick Master” and press the input key.
It will ask “Quick Mastering?”, so select F4 Yes.
It will display “Mastering complete!”.
④ Alignment
Next, move the cursor to the “CALIBRATE” and press the input key.
It will ask “Calibrate?”, so select F4 Yes.
Robot Calibrated! will be displayed.
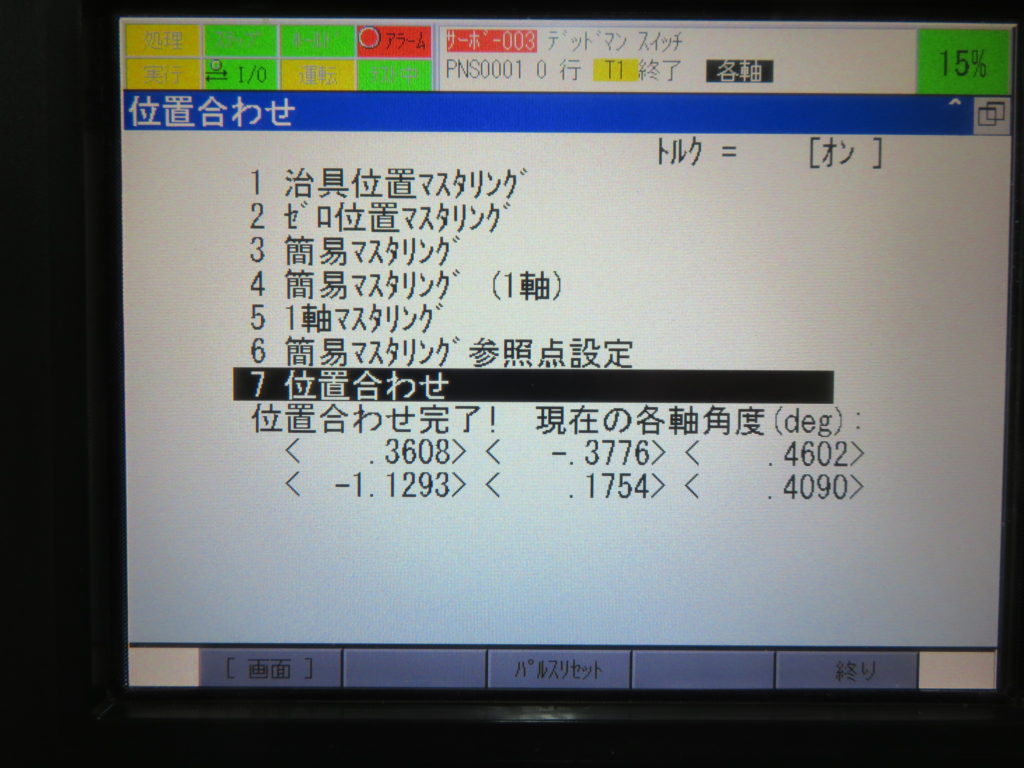
That completes the basic mastering.
At any rate, it seems to be back to normal.
So, how did it go? Did your companions recover safely?
The lesson learned was, “Replace batteries regularly.”

コメント